Head of Research Group: Dr. Tamás Zsedrovits
Members of the Group: Dr. Nawar AL-HEMEARY, Lóránt DAUBNER, Gergő TÉTÉNY BOR, Dániel UJHELYI, Olivér ZSUMBERA
Contact: zsedrovits.tamas@itk.ppke.hu
The UAV Vision Lab aims to explore the intersection of unmanned aerial vehicles (UAVs) and computer vision. A key research focus is optimizing computational tasks for UAVs to achieve minimal power consumption using compact, cost-effective tools. One primary research area is camera-based collision avoidance, which involves detecting and tracking distant aircraft through one or more camera feeds. The goal is to create an efficient collision avoidance system with low power consumption and small size, essential for real-time onboard processing. Another research focus is on ergonomic control methods for UAVs, aiming to develop more natural, quicker-to-learn, and more precise piloting techniques compared to current standards.
A third significant research area involves indoor applications of UAVs, utilizing machine vision to perform tasks without relying on external reference systems, using only onboard sensors such as cameras, IMUs, and LiDAR. For example, in 3D cave mapping, the lab aims to use these sensors to create highly accurate 3D maps of cave passages, enhancing the discovery of new paths and assisting cavers. Additionally, students at the lab work on various projects, including developing simulators for collision avoidance, creating 3D building models with photogrammetric tools, face recognition and tracking with drone swarms, neuromorphic collision avoidance, visual indoor navigation, and building a video annotation database.
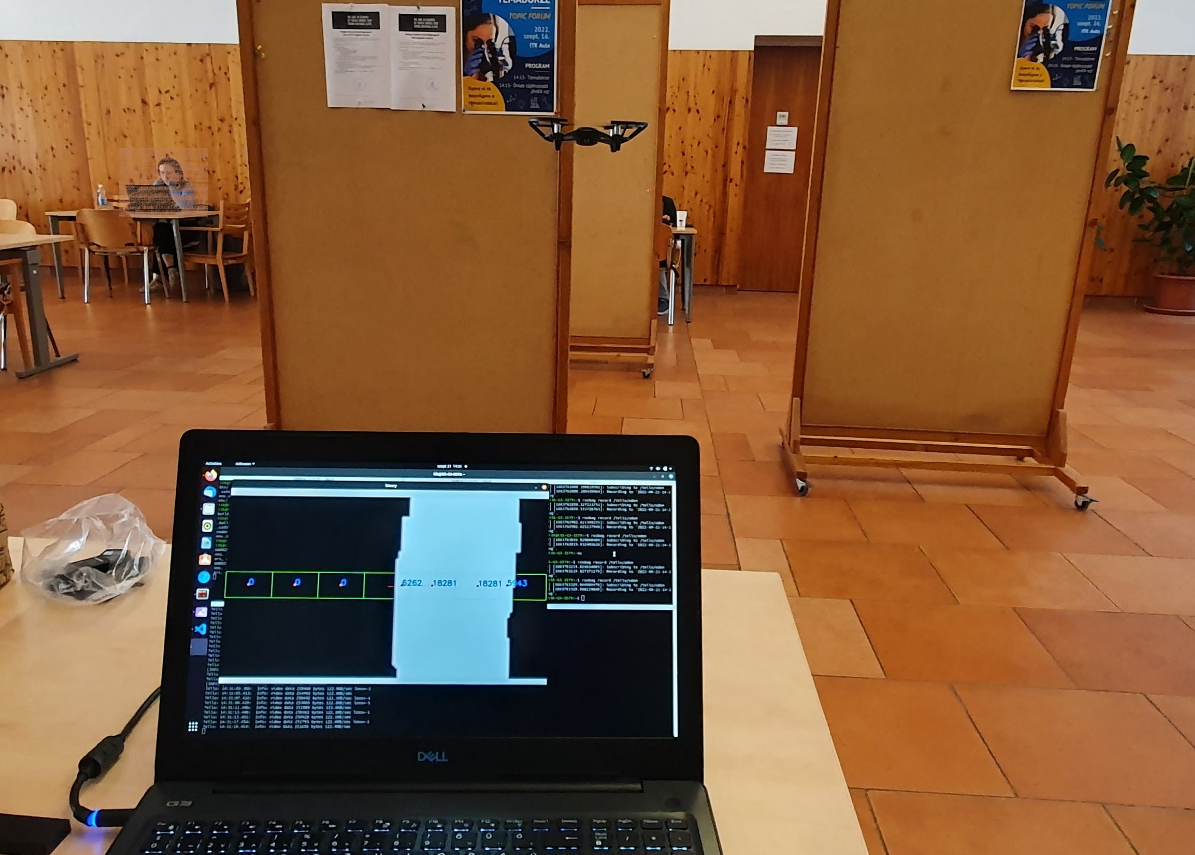
Experiment with a bio-inspired vision system for autonomous obstacle avoidance on drones. The image shows the drone flying through the clear path between the display panels in a complex environment. The system consists of pre-processing based on a mammal retina model and a U-Net for the vision task. The video is recorded by a DJI Tello drone and streamed to a laptop running ROS on Ubuntu, which handles drone control and communication, while the neural network—implemented in PyTorch—runs on the laptop’s dedicated GPU.neural network with a PyTorch-based implementation on the laptop’s dedicated GPU.
Future research directions, collaboration opportunities
The UAV Vision Lab contributes to grant-based collaborations in UAV computer vision, onboard AI, and 3D mapping, with a focus on resource-constrained onboard processing, multimodal sensor data analysis, open-set recognition, and real-world drone validation. The research group provides expertise for joint R&D projects, demonstrators, and student research topics.
Key publications
- Halász A.P., Al Hemeary N., Daubner L.S., Juhász J., Zsedrovits T., Tornai K. (2025). Adapting a Previously Proposed Open-Set Recognition Method for Time-Series Data: A Biometric User Identification Case Study. ELECTRONICS (SWITZERLAND), 14 (20), art. no. 3983.
- Hiba A., Sántha L.M., Zsedrovits T., Hajder L., Zarandy A. (2020). Onboard visual horizon detection for unmanned aerial systems with programmable logic . ELECTRONICS (SWITZERLAND), 9 (4), art. no. 614.
- Zsedrovits T., Bauer P., Hiba A., Nemeth M., Jani Matyasne Pencz B., Zarandy A., Vanek B., Bokor J. (2016) . Performance Analysis of Camera Rotation Estimation Algorithms in Multi-Sensor Fusion for Unmanned Aircraft Attitude Estimation. JOURNAL OF INTEL-LIGENT AND ROBOTIC SYSTEMS: THEORY AND APPLICATIONS, 84 (1-4), pp. 759 - 777.